Real-Time LiDAR Gaussian Splatting SLAM
Seungjun Tak, Yewon Jeon, Jaeik Hwang, SukMin Hwang, Seongbo Ha, and Hyeonwoo Yu
In European Conference on Computer Vision (ECCV), 2026
SLAM · 3D Scene Representation · Robot Perception
Integrated M.S.–Ph.D. Program
Sungkyunkwan University
I am a graduate student in Intelligent Robotics, advised by Prof. Hyeonwoo Yu. Previously, I received my B.S. in Electrical Engineering with a minor in Future Mobility from the University of Ulsan.
My research interests lie in SLAM, 3D scene representation, and robot perception. I have mainly worked on real-time dense SLAM using expressive 3D scene representations. I am also interested in building SLAM systems that operate on real robotic platforms and remain practical beyond controlled laboratory settings. Recently, I've been exploring what information a robot should keep in its map, how that information should be represented, and how such representations can be coupled with SLAM to support downstream tasks.
Integrated M.S.–Ph.D. Program in Intelligent Robotics
Lab of Artificial Intelligence & Robotics (LAIR) · Advisor: Prof. Hyeonwoo Yu
B.S. in Electrical Engineering, Minor in Future Mobility (GPA: 4.4 / 4.5)
Seungjun Tak, Yewon Jeon, Jaeik Hwang, SukMin Hwang, Seongbo Ha, and Hyeonwoo Yu
In European Conference on Computer Vision (ECCV), 2026
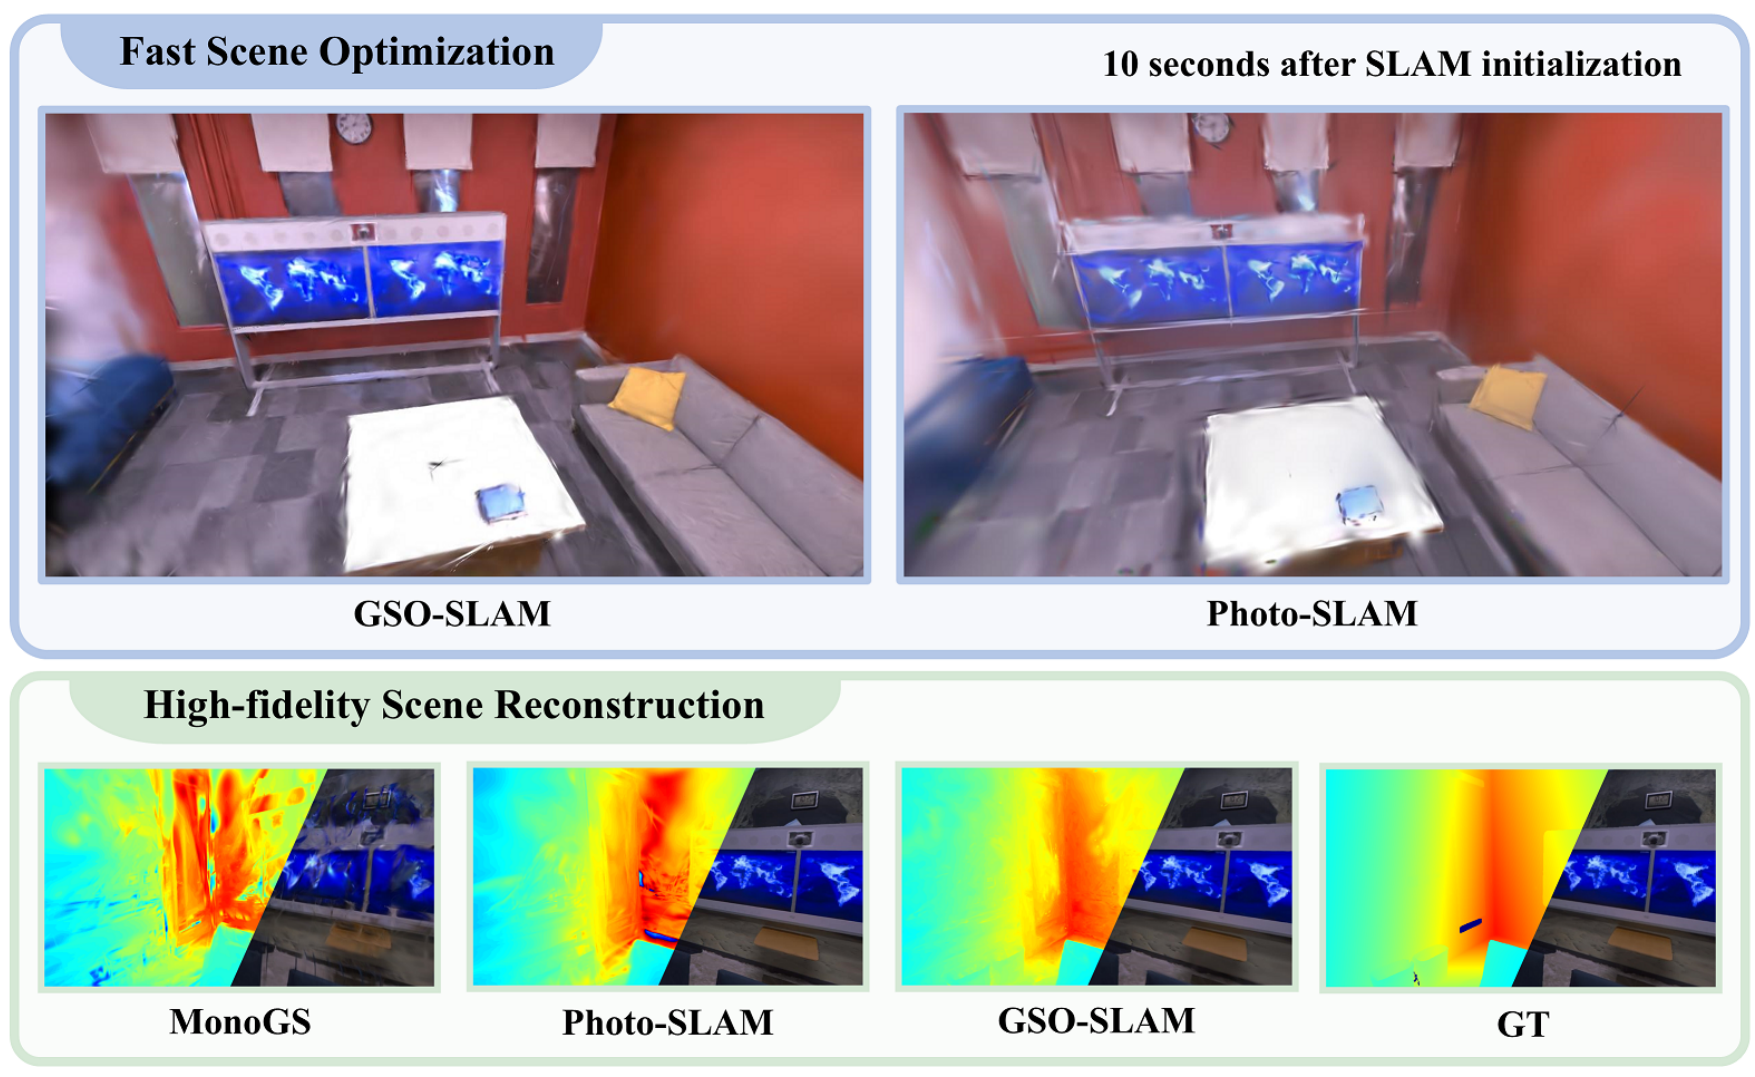
Jiung Yeon*, Seongbo Ha*, and Hyeonwoo Yu (* equal contribution)
IEEE Robotics and Automation Letters (RA-L), 2026
Seongbo Ha, Sibaek Lee, Kyeongsu Kang, Joonyeol Choi, Seungjun Tak, and Hyeonwoo Yu
arXiv preprint arXiv:2602.06991, 2026
Sibaek Lee, Seongbo Ha, Kyeongsu Kang, Joonyeol Choi, Seungjun Tak, and Hyeonwoo Yu
arXiv preprint arXiv:2511.16144, 2025
Kyeongsu Kang, Seongbo Ha, Sibaek Lee, and Hyeonwoo Yu
IEEE Robotics and Automation Letters (RA-L), 2025
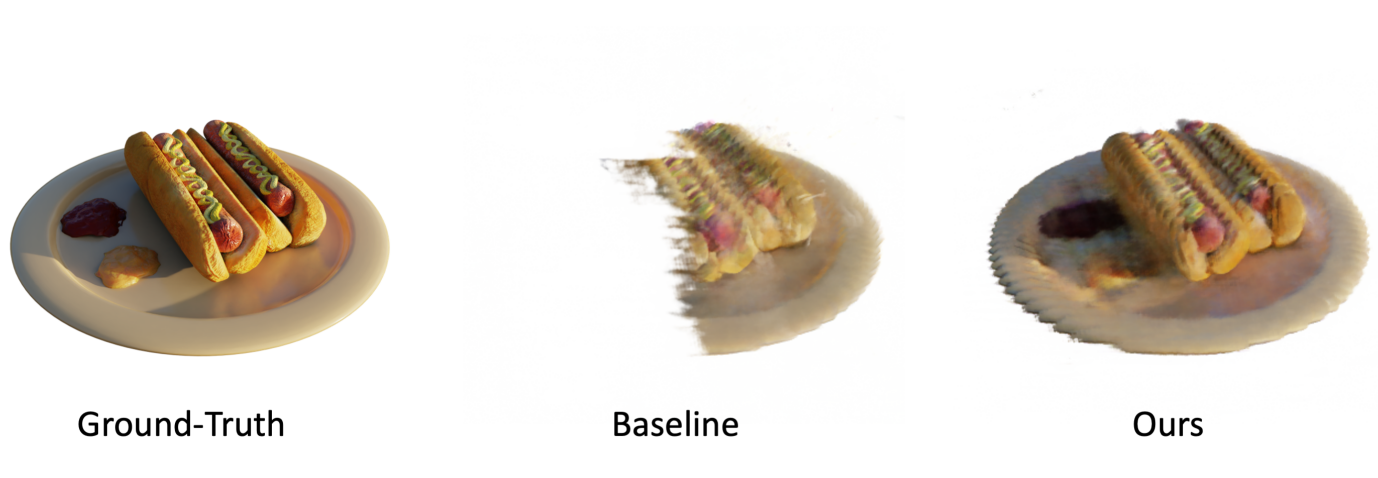
Sibaek Lee, Kyeongsu Kang, Seongbo Ha, and Hyeonwoo Yu
IEEE Robotics and Automation Letters (RA-L), 2025
Seongbo Ha, Jiung Yeon, and Hyeonwoo Yu
In European Conference on Computer Vision (ECCV), 2024
A dense RGB-D SLAM system combining Gaussian Splatting with ICP for high-quality, real-time mapping.
Jehwan Choi, Seongbo Ha, Youlkyeong Lee, and Kanghyun Jo
In the 62nd Annual Conference of the Society of Instrument and Control Engineers (SICE), 2023
Seongbo Ha, Seongmin Kim, and Kanghyun Jo
In KSIC, 2022
Seongbo Ha and Kanghyun Jo
In ICROS, 2022
Seongmin Kim, Seongbo Ha, Kyeongmin Yu, and Kanghyun Jo
In KSIC, 2021
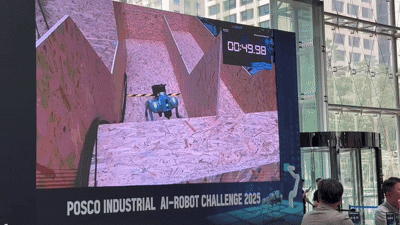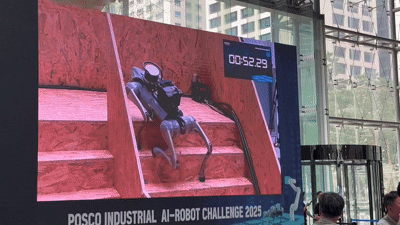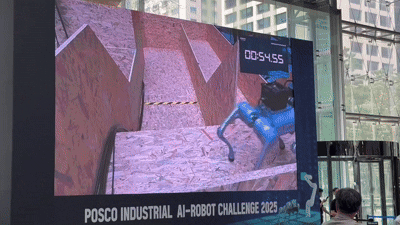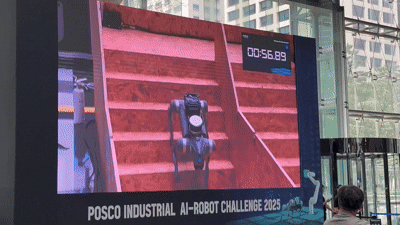
First-prize-winning robotic system developed for an industrial AI challenge.
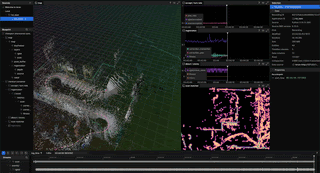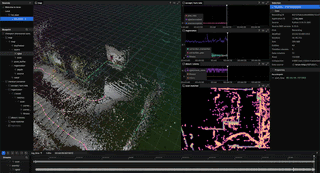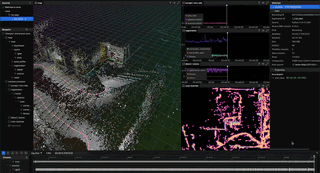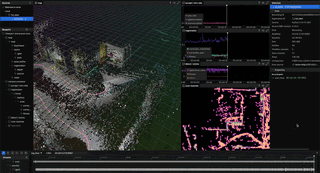
Early-stage project — development underway.
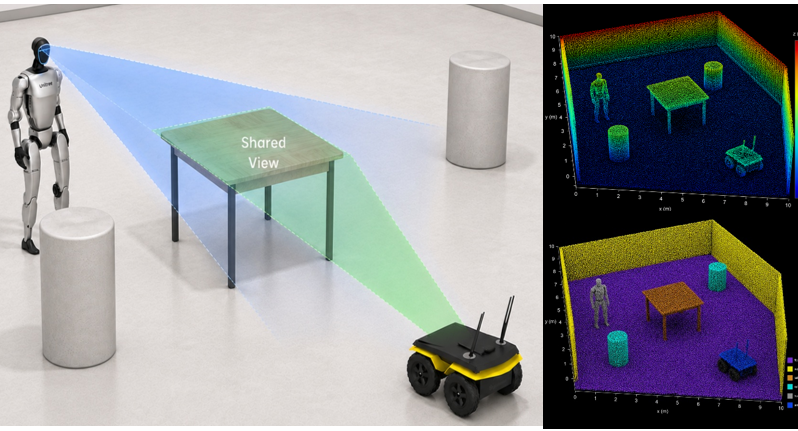
Early-stage project — development underway.
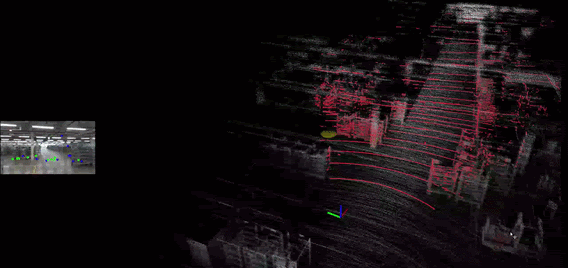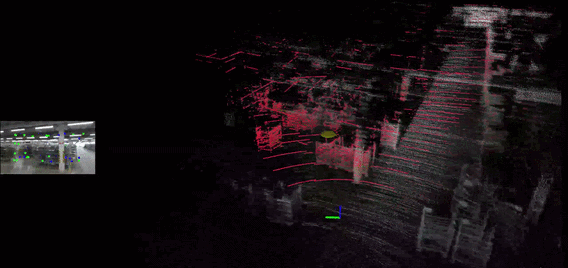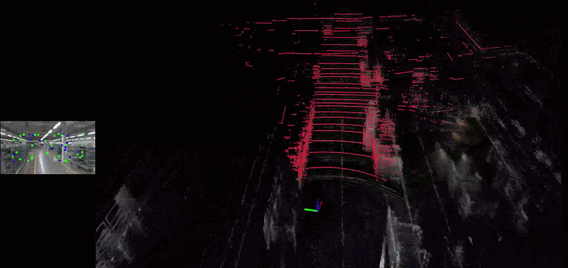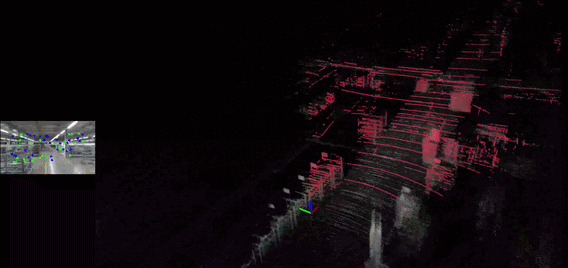
Low-latency LiDAR-inertial SLAM and localization running onboard a drone with an embedded computer.
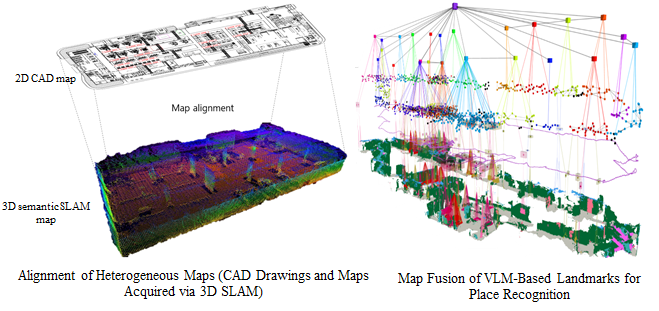
Localization on 2D CAD drawings by aligning 3D SLAM maps to the CAD coordinate frame.
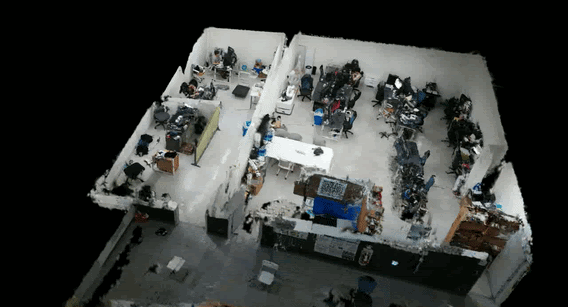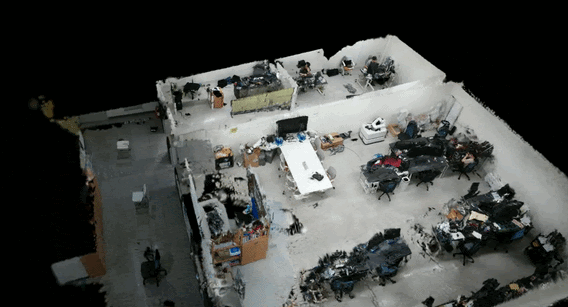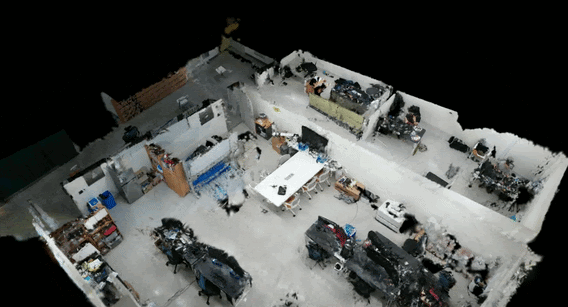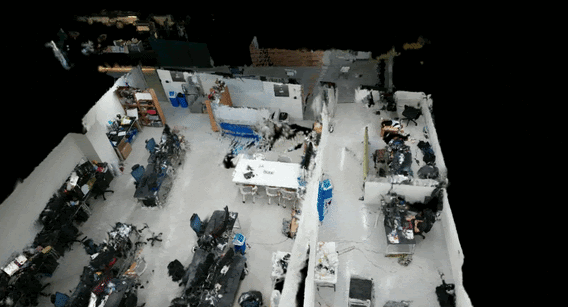
Real-time RGB-D SLAM on an embedded platform, building high-fidelity 3D Gaussian Splatting maps within minutes.
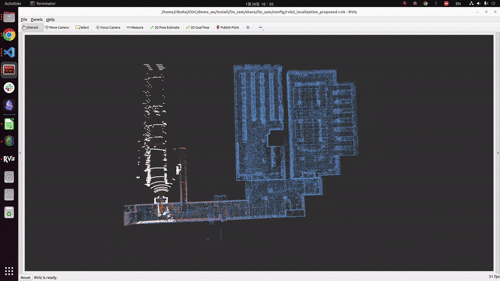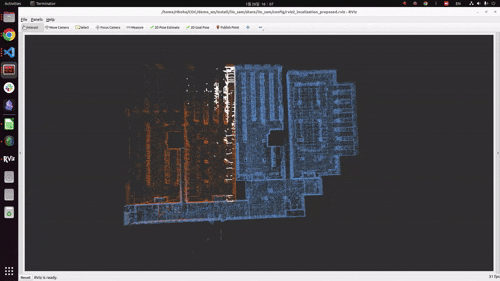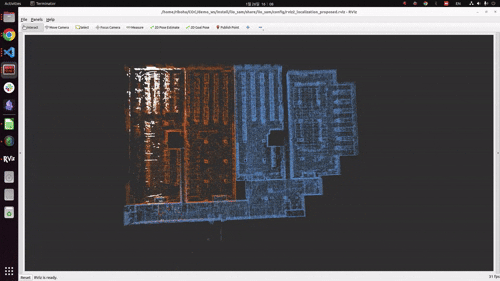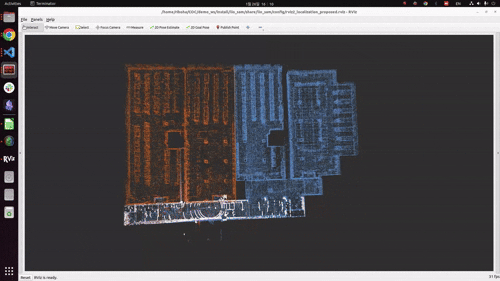
A framework for robust localization in environments that have changed since mapping.
Sungkyunkwan University · IITP grant funded by MSIT
Robotic manipulation of thin, non-rigid objects for battery-pack recycling · MOTIE
Visualization for field deployment and 6-axis rotational angle sensing · MOTIE
Spatial and task generalization framework · NRF
First Prize
Invited Talk
Full Scholarship
Outstanding Paper Presentation Award
First Prize
Second Prize
Outstanding Paper Presentation Award